About Me
Hi, I'm Hongliang Lu (卢鸿良), a junior undergraduate student at Shanghai Jiao Tong University, majoring in Artificial Intelligence. I am currently a research intern at SJTU MVIG-RHOS Lab (advised by Prof. Yonglu Li and Prof. Cewu Lu), focusing on robotic learning from human priors and reinforcement learning. I also work with Prof. Yulun Zhang on model quantization and inference acceleration for generative models.
My research interests include:
- Embodied AI & Robotics: Vision-Language-Action Models, Human Prior Learning, Reinforcement Learning for Manipulation
- Model Efficiency: Quantization, Inference Acceleration, Caching Mechanisms
Feel free to reach out if you're interested in collaboration! I'm actively seeking Summer 2026 research internships.
📄 My CV is available here: Curriculum Vitae (PDF)
🔥 News
2026.05
Paper accepted to ICML 2026: Q-DiT4SR
2025.11
Started research internship at SJTU Computer Vision Lab
2024.09
Started research internship at SJTU MVIG-RHOS Lab
📚 Publications
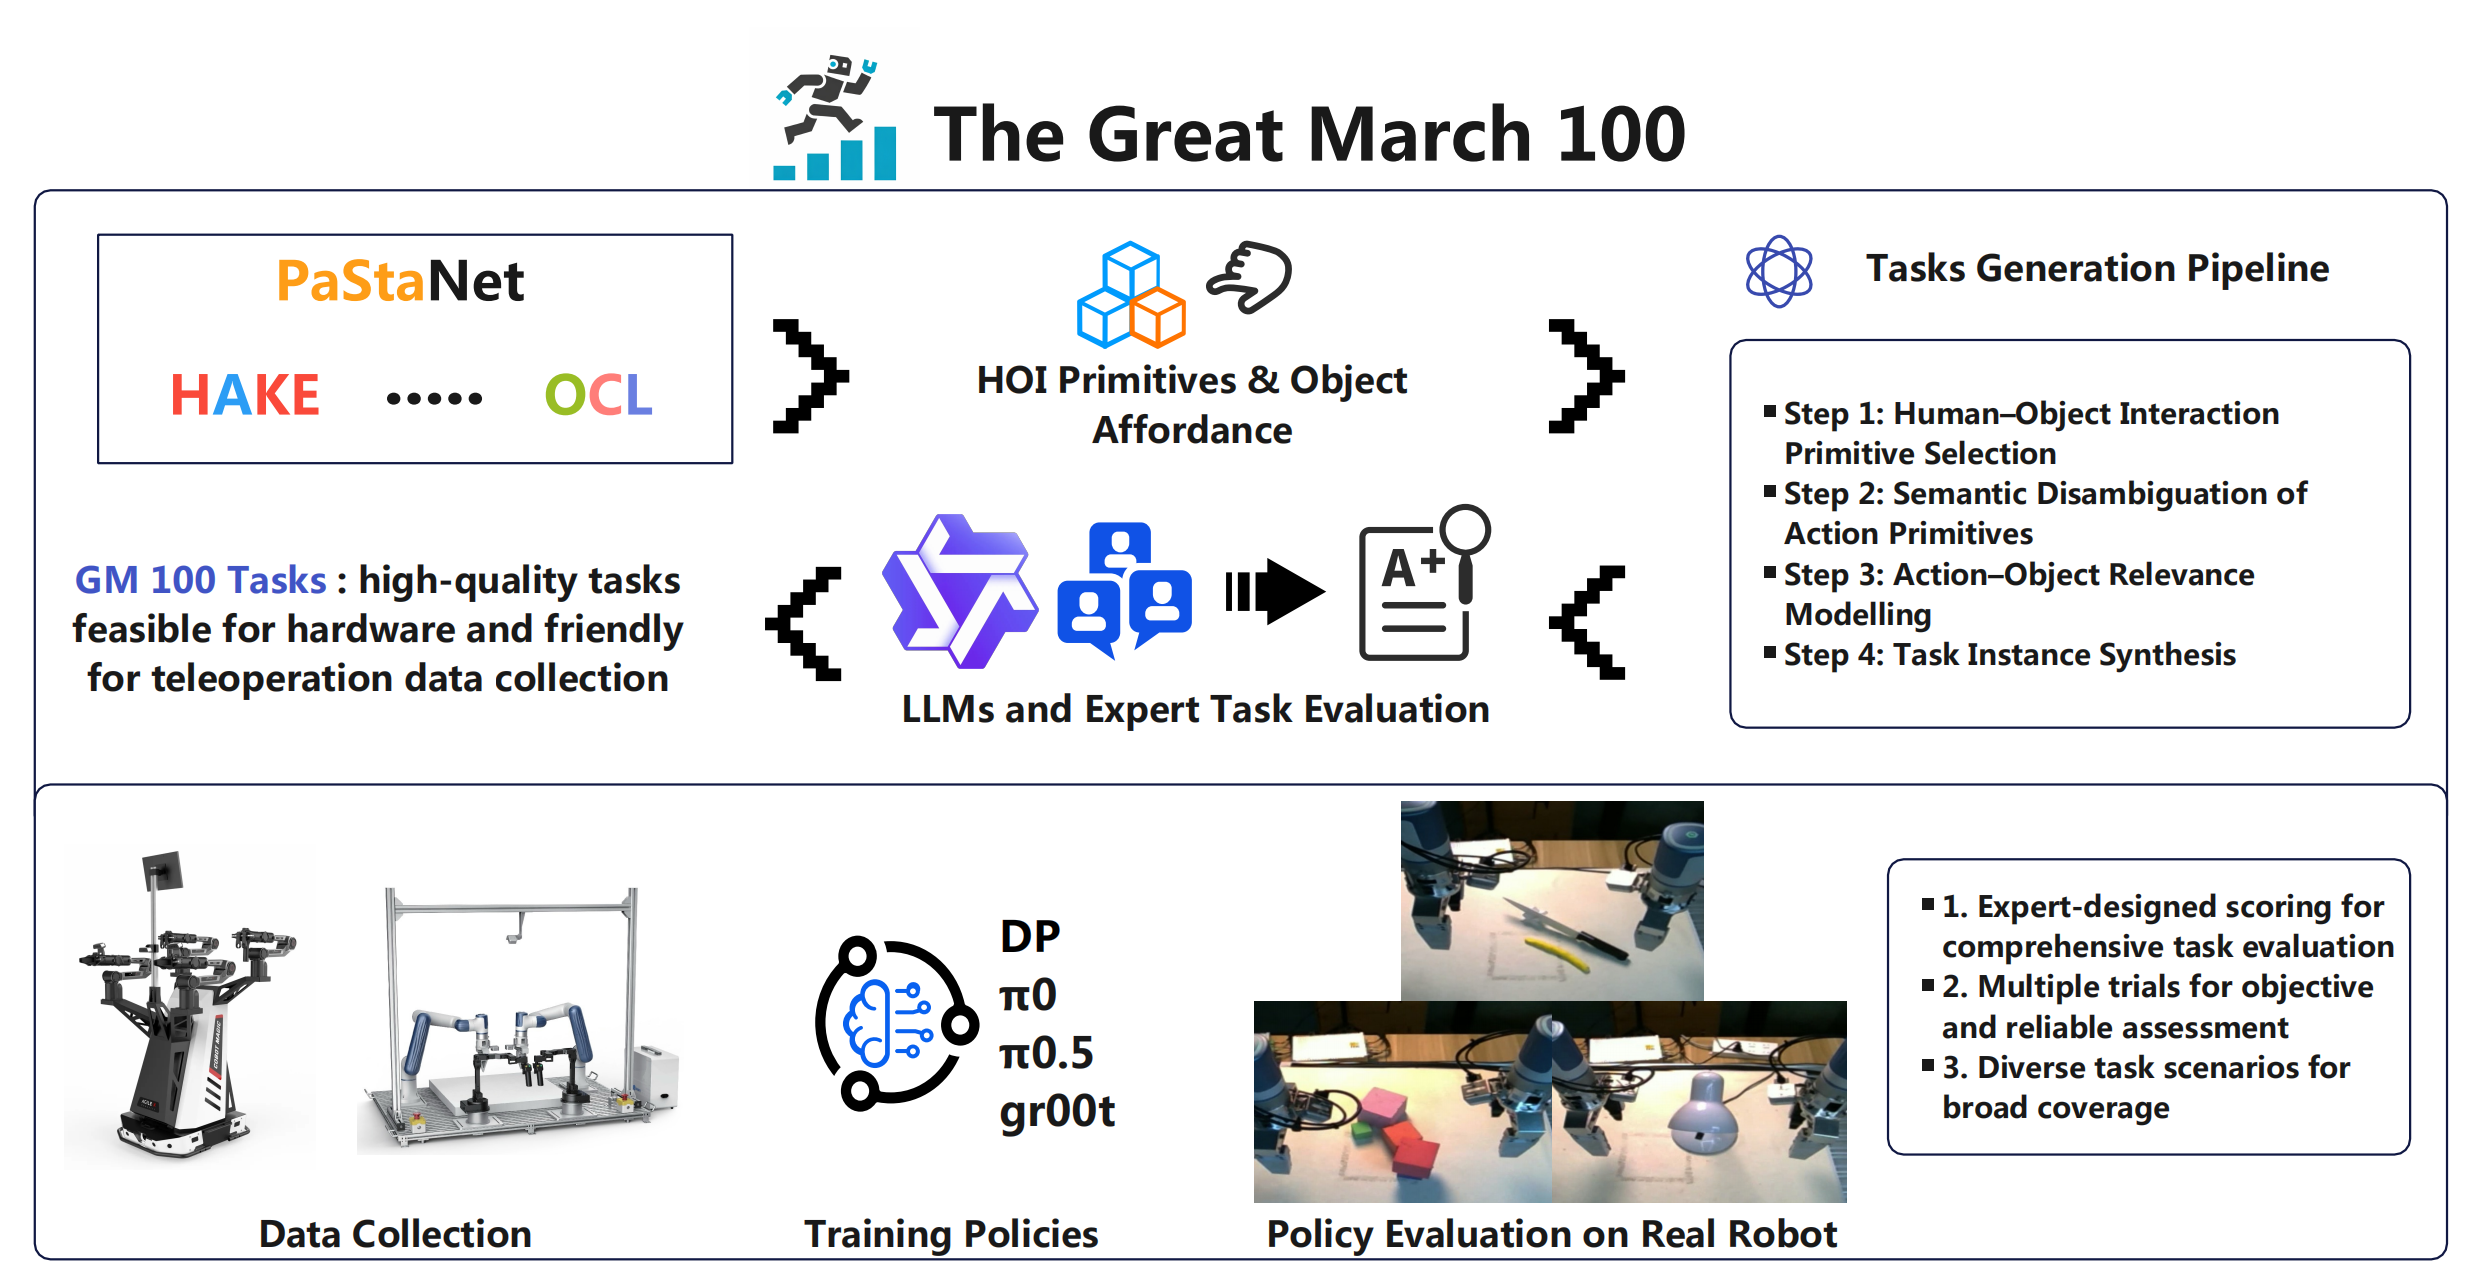
The Great March 100: Detail-Oriented Tasks for Evaluating Embodied AI Agents
Developed a 100-task benchmark evaluating embodied AI across six design dimensions including physics, semantics, and temporal reasoning. Comprehensive evaluation revealed critical limitations in fine-grained manipulation capabilities of state-of-the-art models.
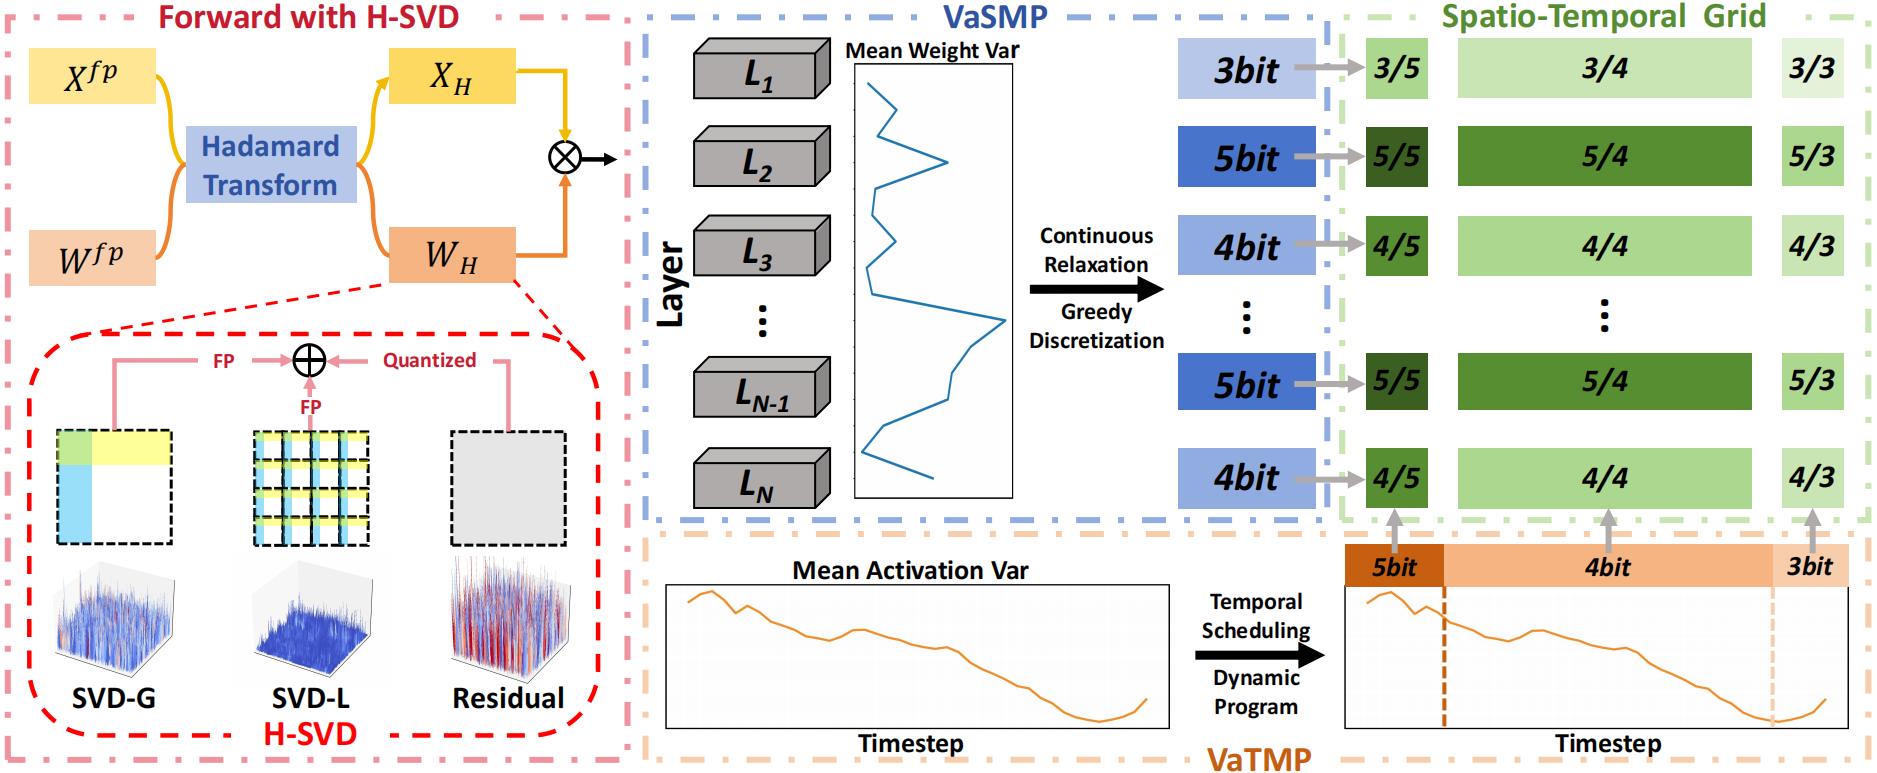
Q-DiT4SR: Exploration of Detail-Preserving Diffusion Transformer Quantization for Real-World Image Super-Resolution
ICML 2026
Developed a quantization framework for Diffusion Transformer super-resolution models, achieving W4A4 precision with minimal quality loss through hierarchical SVD reconstruction and timestep-aware mixed-precision strategies.
💼 Research Experience
Sep. 2024 - Present
Research Intern
Advisors: Prof. Yonglu Li & Prof. Cewu Lu
Research Focus: Robotic Learning from Human Priors and Reinforcement
Key Contributions:
Research Focus: Robotic Learning from Human Priors and Reinforcement
Key Contributions:
- Led real-robot RL experiments using the HILSERL framework, deploying multiple teleoperation modes (Koch arm, VR) on Flexiv manipulator
- Successfully trained policies for high-precision tasks including USB insertion and bottle-cap manipulation
- Contributed to building a three-stage generative framework leveraging human video pretraining to reduce robot data requirements
- Deployed state-of-the-art models (Pi0 series, Diffusion Policy, ACT) from fine-tuning to real robots
Nov. 2025 - Present
Research Intern
SJTU
Advisor: Prof. Yulun Zhang
Research Focus: Model Quantization and Inference Acceleration
Key Contributions:
Research Focus: Model Quantization and Inference Acceleration
Key Contributions:
- Developed quantization frameworks for Diffusion Transformer models achieving W4A4 precision
- Proposed training-free acceleration methods for Rectified Flow models with 4x+ speedups
- Contributed to one paper submitted to ICML 2026
🎓 Education
Sep. 2023 - Jun. 2027 (Expected)
B.Eng. in Artificial Intelligence
GPA: 4.15 / 4.3 | Ranking: 1/100 (Top 1%)
🎨 Miscellaneous
Technical Skills
- Programming Languages: Python, C++
- ML/DL Frameworks: PyTorch, OpenPI, LeRobot
- Robotics: ROS, Flexiv, Aloha, Xtrainer robot arms, IsaacSim, Mujoco
- Tools & Technologies: Linux, Docker, Git, Weights & Biases
Languages
- Mandarin (Native), English (Fluent)
- GRE: Total 330 (Verbal 160, Quantitative 170), Analytical Writing 3.5
- TOEFL: Total 113 (Reading 30, Listening 30, Speaking 24, Writing 29)
Awards & Honors
- A-Level Scholarship (Top 1%), SJTU, 2023-2024, 2024-2025
- Meritorious Winner, Mathematical Contest in Modeling (MCM), 2024
- Second Prize, 16th National College Mathematics Competition (Non-Math Category A), 2024
Sports
- Table Tennis, Badminton
Hobbies & Interests
- Photography, Film, Model Making, Painting